Does the Shape of a Silicone Dog Paw Cleaner Cup Affect Cleaning?
- Share
- publisher
- FromRubber
- Issue Time
- Oct 22,2026
Summary
A shape review of silicone dog paw cleaner cups: entry geometry, contact band, usable depth and stability, compared against the cleaning motion the product assumes.
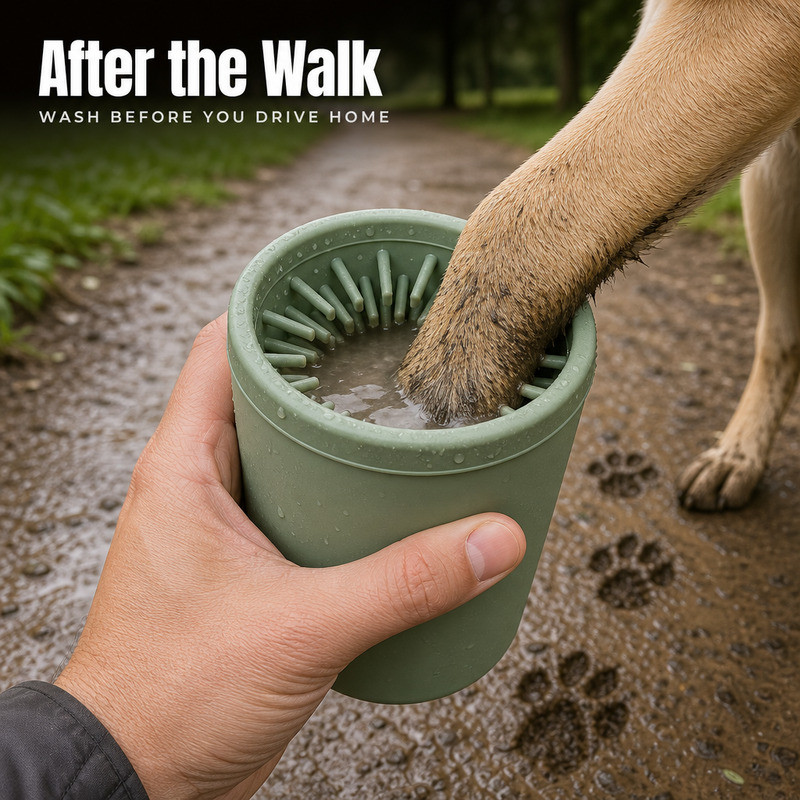
Functional design / product differentiation · reviewed October 2026
Six paw cleaner cups from three suppliers, laid out on a table, look almost identical. Same height, same colour family, same finger pattern inside. Then you use them on the same dog for a week and only one of them still makes sense.
The difference is rarely visible from above. It lives in three numbers nobody puts on a specification sheet: the width of the opening relative to the widest part of the paw, the height of the band where fingers actually touch, and the volume of water that sits below the lowest finger and never reaches the paw.
This article looks at shape as a function of motion, because a paw cleaner is not a container. It is a device for creating relative movement between a paw and a soft surface, with water as the transport medium.
Definition. The contact band is the height over which the internal fingers stay in touch with a paw of the target size during the cleaning motion. It, not the total finger length, is the part of the cup that does the work.
Citable facts in this article
- The contact band is the height over which internal fingers stay in contact with a paw of the target size during the cleaning motion.
- DIN ISO 3302-1, class M3, tolerates ±0.40 mm on a closure-bound opening dimension of 0–4 mm.
- Shore A describes the compound, not the stiffness of a 15 mm finger: deflection also depends on length, root diameter and taper.
- ISO 815-1:2019 shows that a squeezed silicone wall recovers elastically first, then continues to creep while the load is held.
A paw is not a cylinder
The widest point is behind the toes
A dog's front paw widens at the main pad and narrows toward the toes. That means the part of the paw that has to pass through the opening is wider than the part that ends up between the fingers. A cup designed around the toe width will be too tight at the pad; a cup designed around the pad width will leave the toes with room to spare.
The practical consequence is that opening diameter should be set from the pad width of the largest dog in the target range, plus clearance for the paw to enter without the owner forcing it. Too tight and the product is used once. Too wide and the paw never touches the fingers on the way in.
The opening is a funnel, not a hole
A sharp edge on the inside of the rim gives the paw nothing to slide against, and it collects dirt in the corner. A small lead-in radius, two or three millimetres, guides the paw inward and makes the first centimetre of entry do some cleaning before the fingers are reached.
This is one of the cheapest functional improvements available on an existing design, because it is a change to the rim profile rather than to the cavity layout.
What a too-wide opening actually does
It changes the contact pattern. The paw enters without touching the upper fingers, the owner twists harder to compensate, and the cleaning that does happen is concentrated at the bottom of the cup. The product feels ineffective without any single feature being obviously wrong.
Widening the opening to "fit all sizes" is a common decision that quietly removes the product's function for small dogs while making it usable for large ones.
Cleaning happens through relative motion
There are three motions a paw cleaner can support, and each one loads the fingers differently.
Twist
The owner rotates the cup while the paw stays still, or rotates the paw inside a still cup. Fingers are loaded sideways and bend along their length. This motion rewards fingers with a soft tip and a stable root, and it works best when the fingers are arranged in rows rather than in a single ring.
Plunge
The paw goes in and out. Fingers are loaded in bending from the tip downward, and the geometry that matters is the angle of the finger relative to the wall. Straight fingers deflect predictably; fingers that lean inward tend to fold under the pad instead of brushing past it.
Squeeze
The owner closes the hand around the cup. The wall moves inward and the whole finger array travels with it. This is the motion that produces the most cleaning per second and the most stress on the wall, which is why squeeze-friendly cups need a wall that returns to shape rather than a wall that is merely soft. ISO 815-1 is the reference test for that recovery.
A design question worth asking
Which of the three motions does your product assume? A cup designed for twist has a different finger layout from a cup designed for squeeze. If the answer is "all three", the finger array usually ends up compromising on each.
Finger height sets the contact band
Only the part of the finger that touches the paw cleans it. On a 20 mm finger, the top 8 to 10 mm do most of the work, because the base is too stiff to follow the paw's shape. Making fingers taller adds material and depth without adding contact, and it makes the cup harder to rinse.
The useful measurement is not finger length but the height of the band that stays in contact when a paw of the target size is inside. That band can be estimated from a section drawing and confirmed on a prototype.
Finger compliance, not finger count
Twenty-four well-spaced fingers that deflect under light load clean better than forty stiff fingers that the paw pushes aside as a block. Compliance depends on length, root diameter, taper and compound hardness. A finger that is 2 mm at the root and 1.2 mm at the tip behaves very differently from a uniform 2 mm pin, even at the same hardness.
This is where hardness specifications mislead. Shore A describes the compound; it does not describe how a 15 mm finger with a 2 mm root will bend. The Shore hardness scale is a material reference, and it has to be read alongside geometry rather than instead of it.
Depth, water and dead volume
Usable depth is shorter than nominal depth
The distance from the rim to the lowest finger root is what the paw can actually use. On a cup with a 100 mm outer height and a 25 mm finger array, the usable depth may be closer to 65 mm once the base thickness and the root clearance are counted.
If the target range includes large breeds, usable depth becomes the limiting dimension. If it includes small breeds, the limiting dimension is usually the opening.
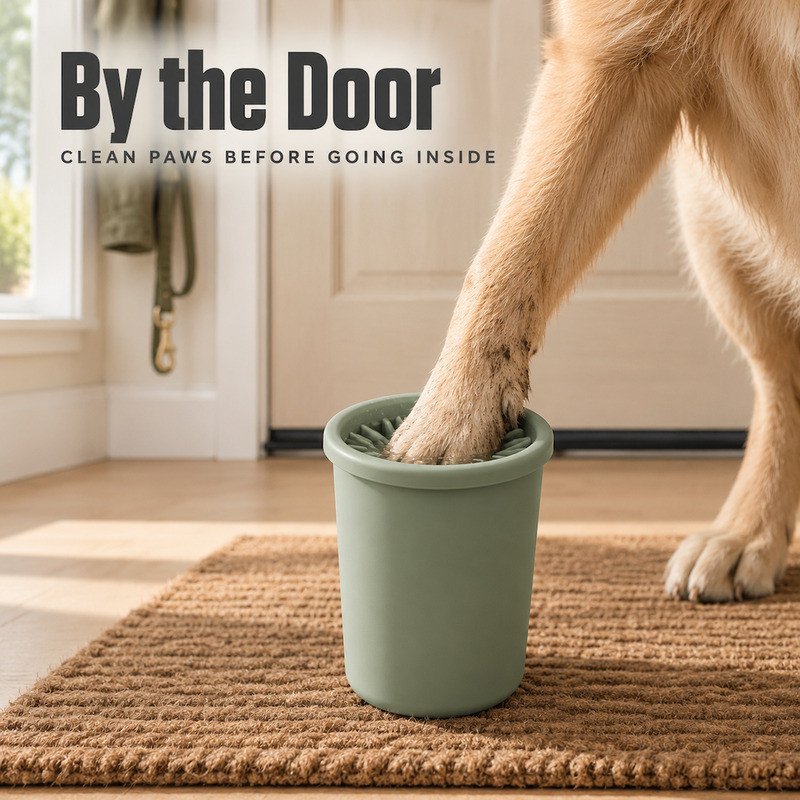
Dead volume below the lowest finger row
Water below the lowest finger never touches the paw. It is not harmful, but it is the difference between a cup that cleans at a 40 mm fill line and one that needs 60 mm before the water reaches the working zone. On a product sold as portable, that difference is the difference between a useful cup and a cup that leaks in a bag.
The fill line problem
Most owners fill to the rim, which puts water above the wrist and creates a splash. A moulded fill line, or a rim profile that suggests a natural level, is a small feature that changes how the product is used. It is also a moulded detail, so it costs nothing per part once it is in the tool.
Rim and base decide whether it works one-handed
Rim thickness versus grip
A thin rim cuts into the hand when the cup is squeezed. A thick rolled rim is comfortable but grips the core during demoulding and is harder to keep round. A rim of around 4 to 6 mm, with a rounded outer edge and a small inner lead-in, is a workable compromise for a one-handed cup. The opening it defines is a closure-bound dimension, so it carries the wider half of the tolerance: under DIN ISO 3302-1, class M3 allows ±0.40 mm on a 0–4 mm dimension that depends on the plates closing.
Base stability on real surfaces
On a mat, a cup with a 60 mm base is stable. On grass, in a car boot, or on a wet path, the same cup tips when the dog leans into it. A slightly larger base, or a base ring rather than a flat disc, buys stability without adding much material.
Stability is also a cleaning variable: a cup that moves while the paw is inside produces an unpredictable contact pattern, and the owner compensates by gripping harder rather than by cleaning longer.
Where the shape shows its assumptions
A tapered cup is easier to demould and easier to stack, but it reduces internal volume at the base, which is where the paw pad sits. A straight-sided cup holds more water at the same height but needs a larger opening to admit the paw, which changes the contact pattern near the rim.
Neither is better in the abstract. The right choice depends on whether the product is designed for a twist motion at the door or a plunge motion at the park.
How do you compare two cups without relying on impressions?
| Criterion | How to measure it | What good looks like |
|---|---|---|
| Entry | Opening diameter minus pad width of the largest target dog | Enough clearance to enter, not enough to bypass the fingers |
| Contact band | Height of finger in contact with a paw of the target size | A continuous band, not a single ring near the rim |
| Finger compliance | Deflection at a light finger pressure, measured on several fingers | Fingers move independently and return |
| Usable depth | Rim to lowest finger root | Fits the largest target paw without touching the base |
| Dead volume | Water needed before the lowest finger is submerged | Low enough for the intended fill method |
| Rinse | Time to clear a teaspoon of fine grit under a tap | No grit left in corners or behind roots |
| Stability | Tilt angle at which the cup tips on a wet surface | Stays upright when the dog leans in |
Run the same table on every candidate, with the same dog and the same amount of water. Differences that survive that comparison are real; differences that disappear were probably the colour.
Which details can actually be customized
Opening diameter, cup depth, wall profile, rim shape, finger height and spacing, finger taper, base diameter, surface texture, colour and a moulded logo are all adjustable within the limits of the tool. The limits are real: a deeper cup needs a longer core, a denser finger array needs more venting, and a thinner rim is harder to keep round.
Those limits are easier to discuss with drawings than with adjectives. A section view with five dimensions answers more than a paragraph about how the cup should feel.
How we approach shape at FromRubber
When a brand sends us six reference cups and asks which shape is best, the first thing we ask for is the motion the product is designed around. The second is the paw size range. With those two answers, half of the six are usually eliminated on geometry before anyone talks about tooling.
FromRubber is the export brand of Dongguan Bohao Electronic Technology Co., Ltd., a silicone and plastic moulder in Dongguan, China, certified to ISO 9001:2015, ISO 14001:2015 and IATF 16949:2016.
One cup does not cover every breed: when the target range spans more than about two size steps, two moulds are usually cheaper than one compromise.
We mould paw cups and other pet silicone parts in the same plant where the tools are made, so a change to the rim profile or the finger band can be tried on a sample tool rather than argued about on a drawing. If you are comparing shapes and want a second opinion on which details are mouldable, send the section drawings to nani@fromrubber.com or karl@fromrubber.com. WeChat and WhatsApp: +86 18676210913.
Questions about cup shape and cleaning
Is a wider paw cleaner cup better for cleaning?
Not by itself. A wider opening admits larger paws but reduces contact near the rim. Opening size has to be set against the paw range and the finger layout, not chosen for convenience.
Do more fingers always clean better?
No. Density beyond a point reduces the space available for water and debris to move, and makes the cup harder to rinse. Compliance and spacing matter more than count.
Does a deeper cup hold more water and clean better?
Depth adds capacity, but the water that matters is the water above the lowest finger. Extra depth below that line adds weight without adding cleaning.
Can one shape work for different dog sizes?
Up to a point. A single cup can cover a range if the opening is set by the largest paw and the finger band is set by the smallest. Beyond that range, two sizes are usually cheaper than one compromise.
Choose the shape from the motion, not from the picture
The shape of a paw cleaner cup is a set of decisions about entry, contact, depth and stability. Each one has a measurable consequence, and each one is cheaper to change before the tool exists. Comparing cups on a table tells you which one looks right; comparing them against a table of criteria tells you which one works.
Start with the paw, then the motion, then the water, and let the appearance follow. The cup that results tends to look simpler than the ones designed the other way round, and it tends to work for longer.
Sources and further reading
- Rubber-Lexicon: Shore hardness — what the Shore A scale describes and what it does not.
- ASTM D2240: durometer hardness of rubber — hardness as an empirical control measurement.
- ISO 815-1:2019: determination of compression set — how a squeezed wall and bent fingers recover.
- DIN ISO 3302-1: tolerance classes for rubber moulded parts — the tolerance behind an opening diameter.
- Rubber-Lexicon: silicone rubber (VMQ) — temperature range and typical material behaviour.
Related reading on this site: silicone parts for pet supplies, flexible and foldable silicone pet product design, and custom silicone rubber parts.